DENEB SYSTEMSGet in touch
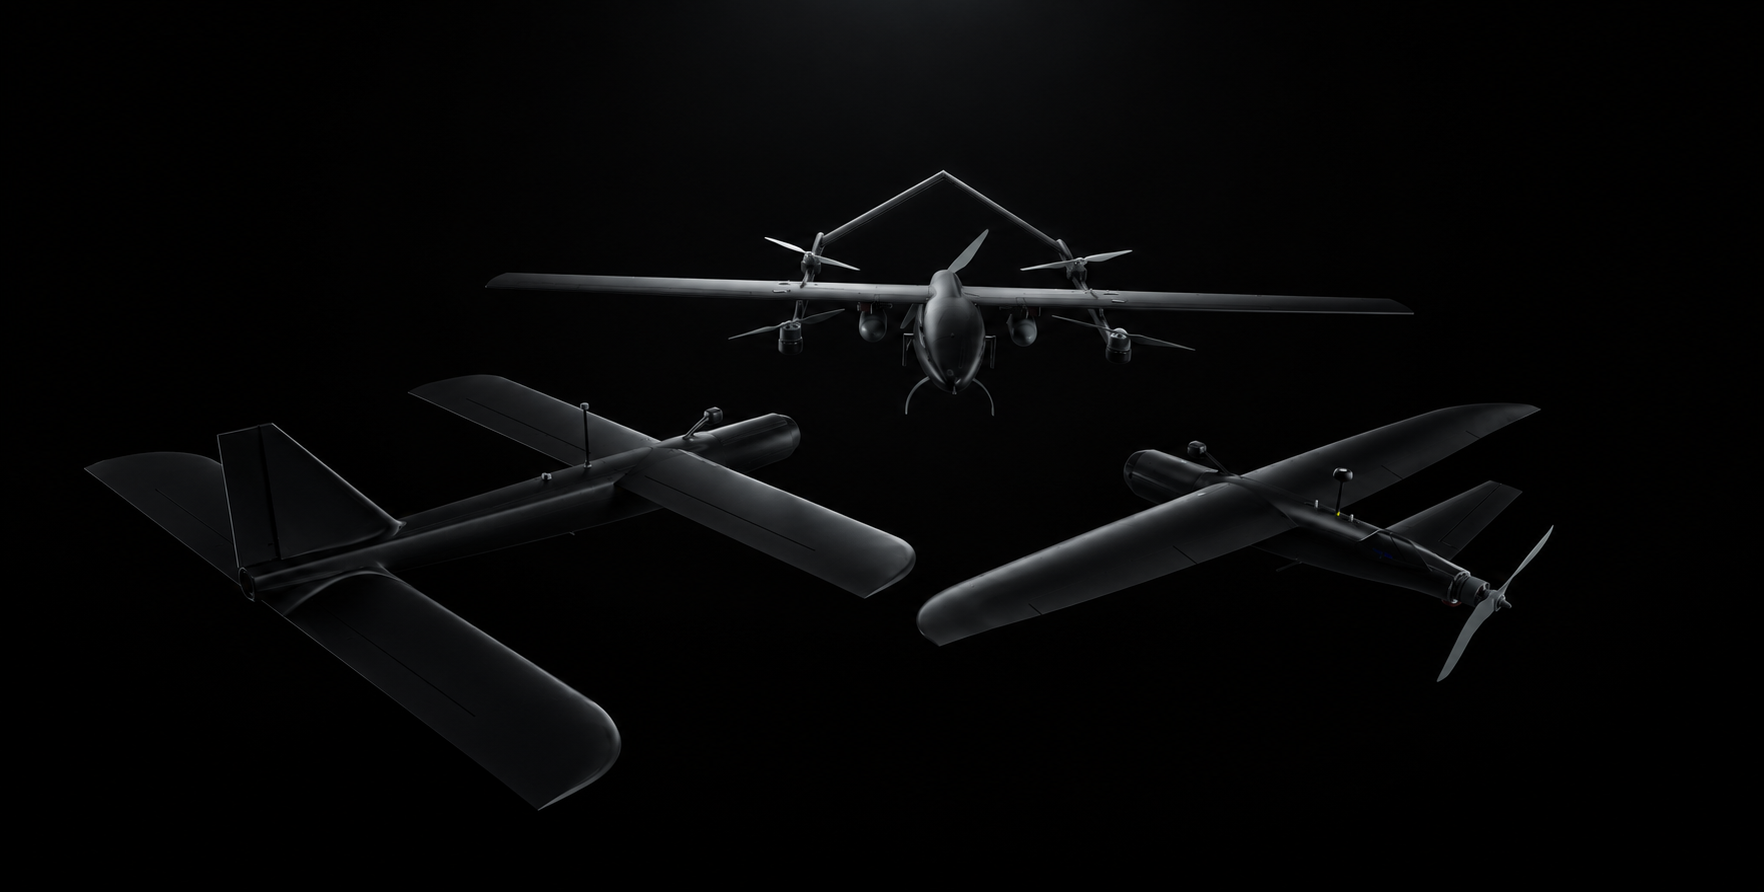
Matte-black autonomous aircraft developed by Deneb Systems

Deneb Systems

Autonomous aircraft, and the systems that fly them.

Raven, Alien, Vulture, and Sky Tracker - perception, guidance, and flight control built as one stack.

See the systems

Products

Autonomous aircraft and the tools that take them from CAD to flight.

Deneb Systems builds the airframes and the perception, guidance, and flight-control software they fly with. Deneb Aero connects aircraft geometry, aerodynamic analysis, and flight simulation in one workspace.

UAV

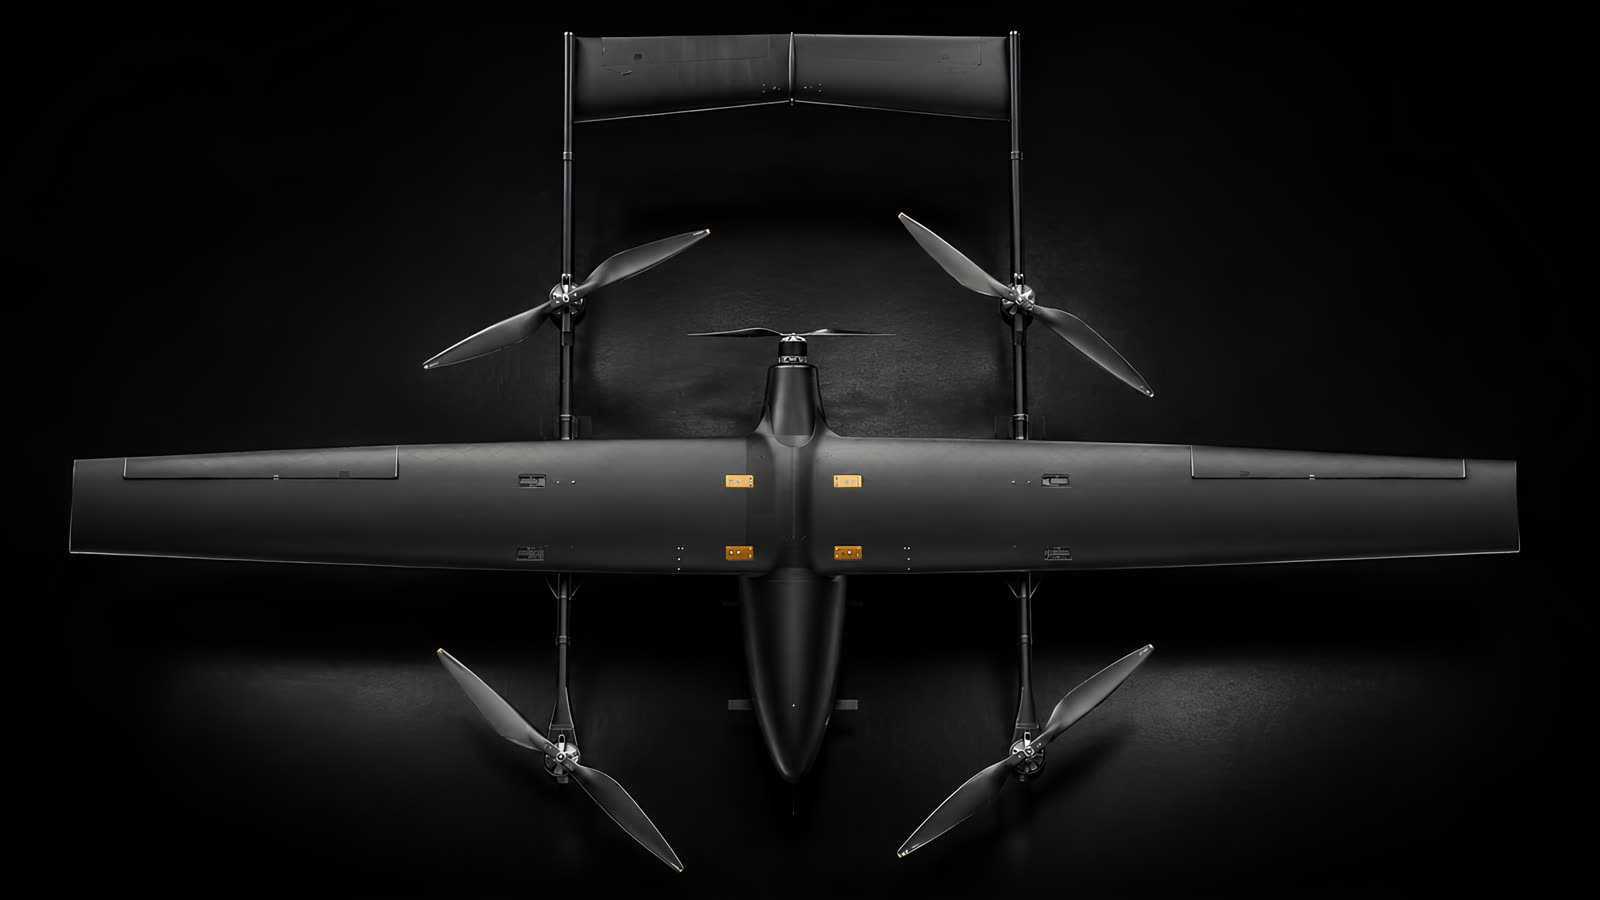
Raven autonomous VTOL UAV by Deneb Systems

Autonomous VTOL platform

Raven

A largely 3D-printed autonomous VTOL aircraft. Raven launches vertically on four lift rotors, transitions to efficient fixed-wing cruise, and runs complete payload-delivery and ISR missions on its own - proven from digital twin to first flight.

Configuration
VTOL quadplane
Airframe
~90% 3D printed
Status
First flight achieved
See Raven
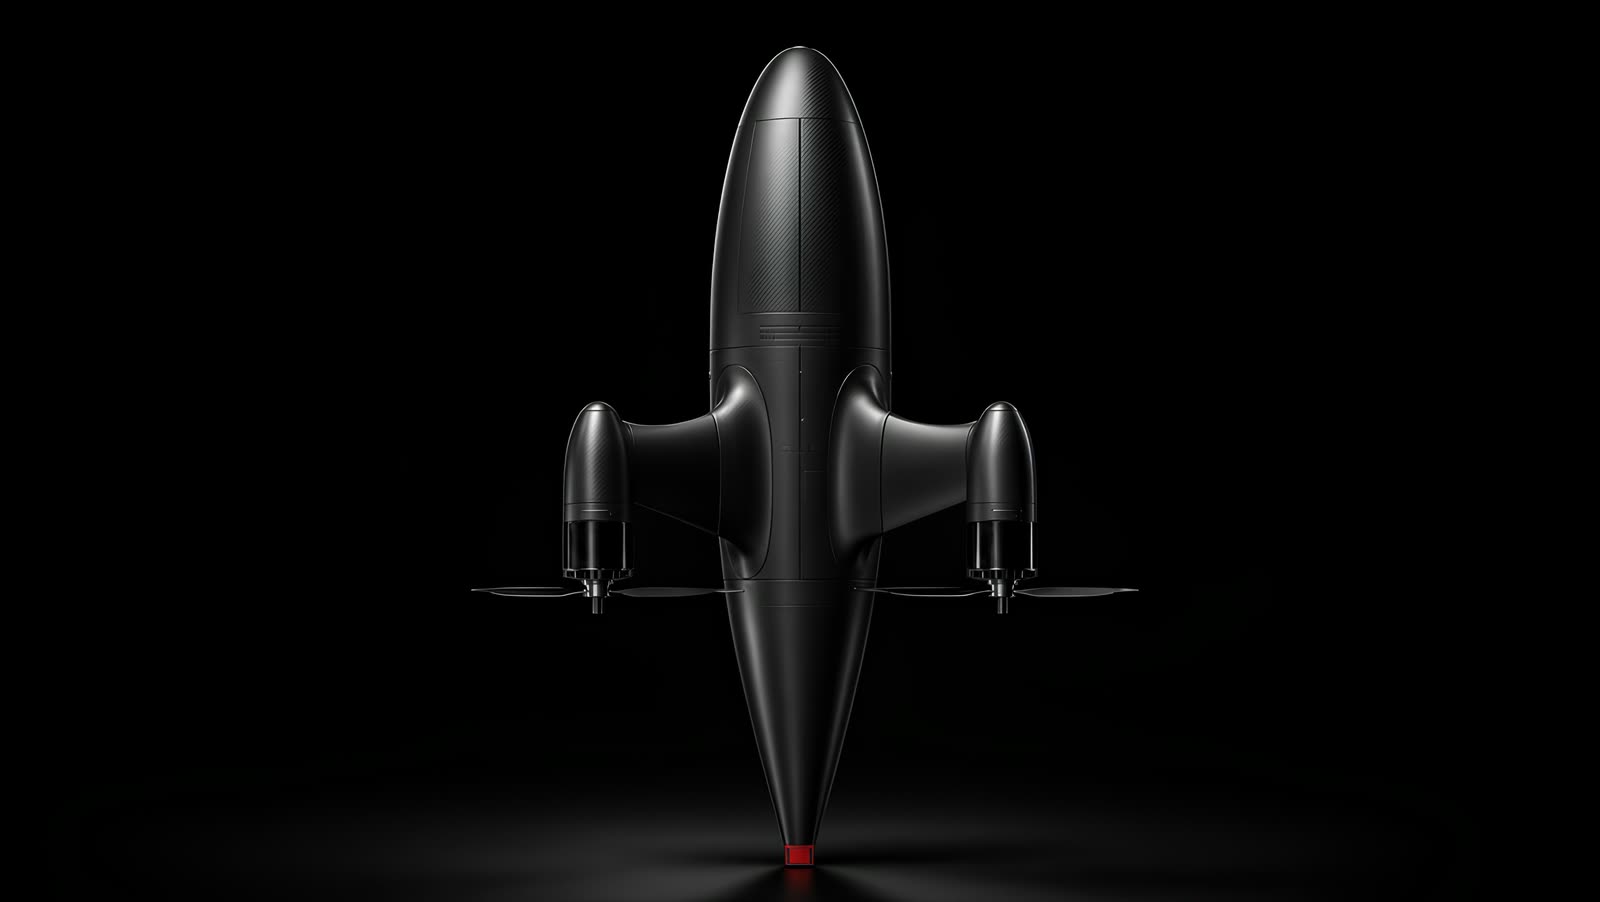
Alien autonomous interceptor aircraft

Autonomous interceptor

Alien

A vision-guided autonomous interceptor development platform. Alien visually acquires an airborne target and continuously corrects its flight path during pursuit - no target GPS required.

Mission
Acquire / Track / Pursue
Guidance
Vision-relative
Status
First flight achieved
See Alien
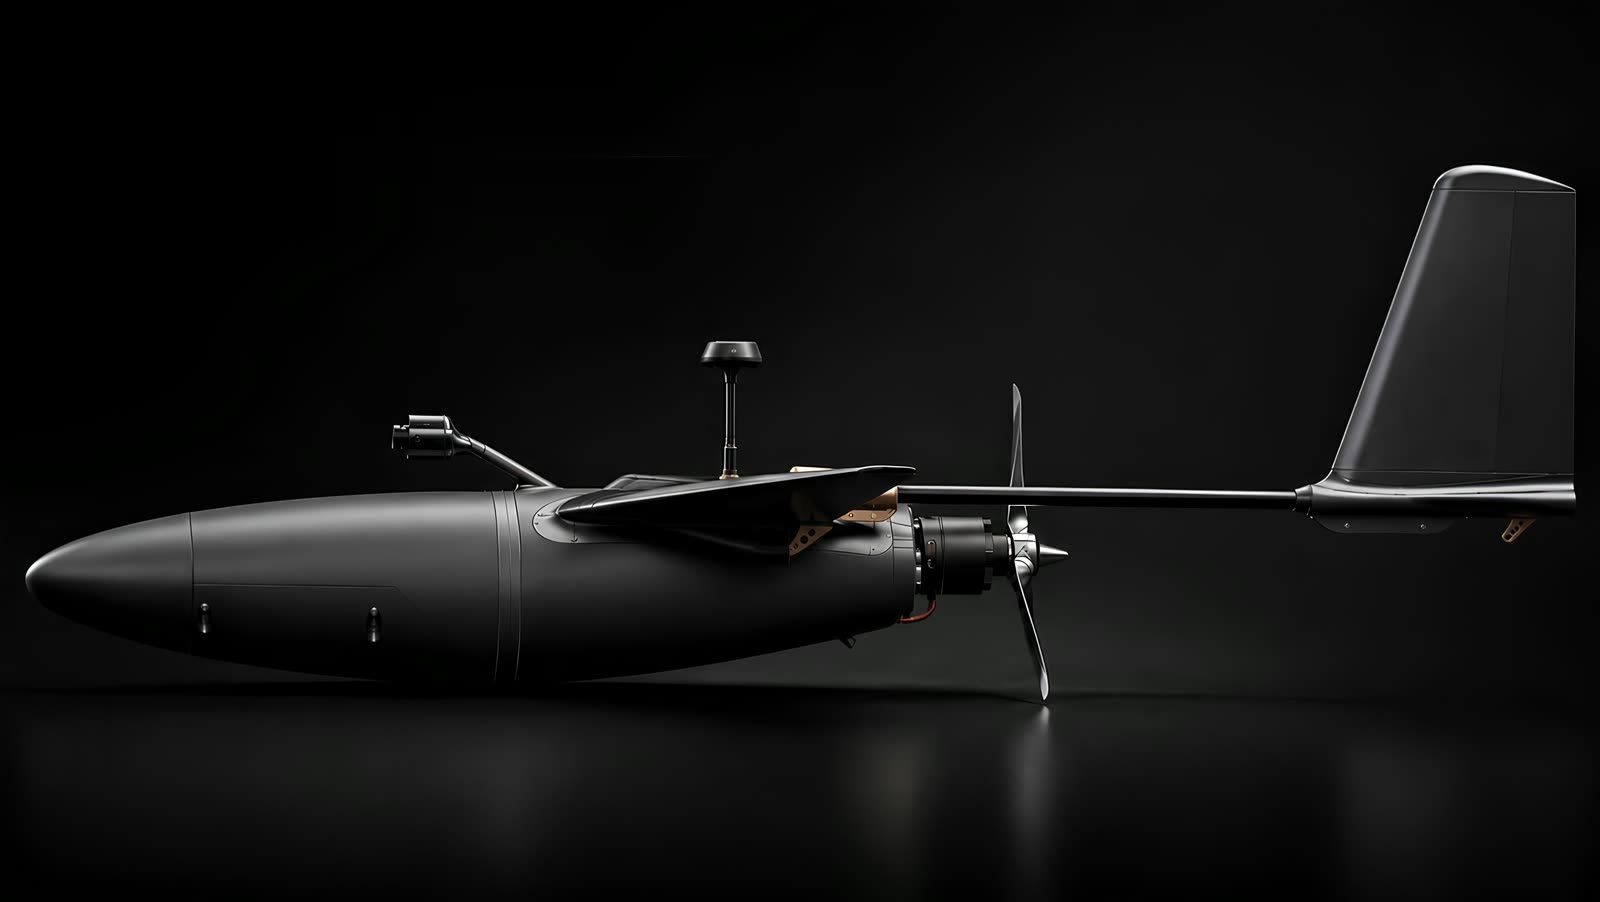
Vulture autonomous loitering munition UAV in flight

Autonomous loitering munition UAV

Vulture

Vulture is an autonomous loitering munition UAV designed to find, identify, and destroy selected targets.

Role
Loitering munition
Mission
Find / identify / destroy
Status
First flight achieved
See Vulture

Software

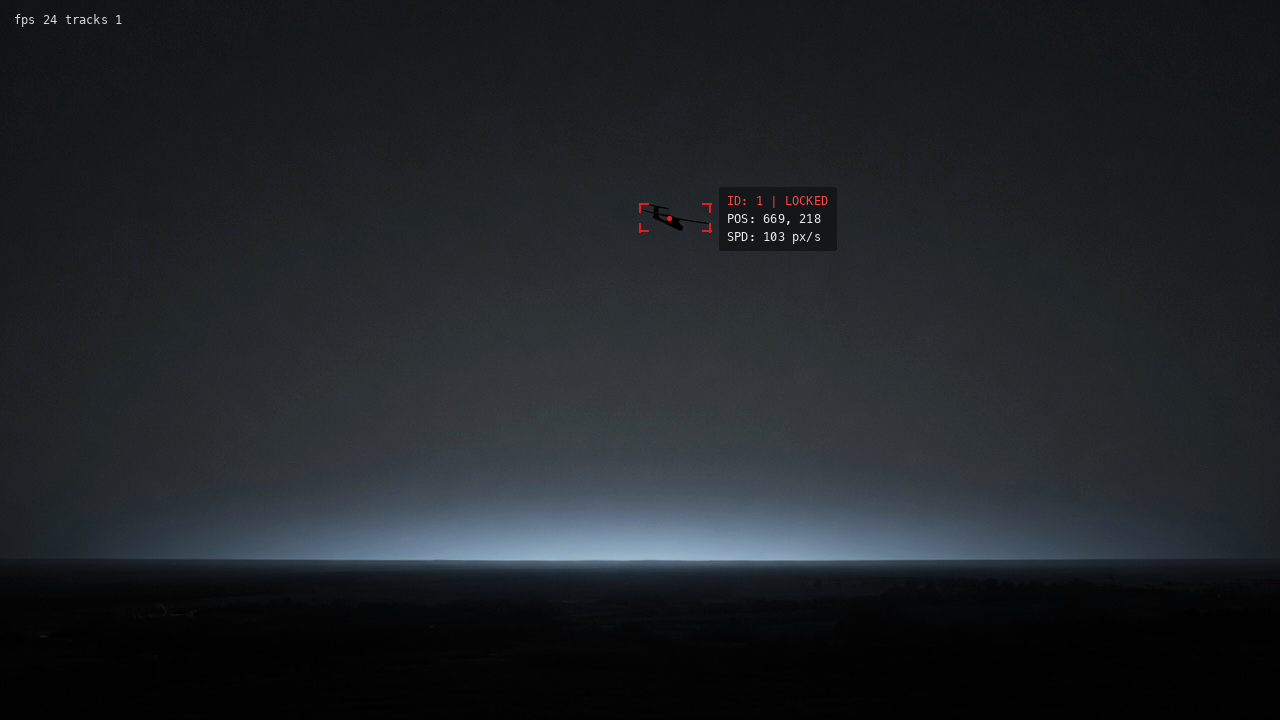
Sky Tracker lock on a small aircraft: red corner brackets, ID, position, and speed on dark sky footageZoomed Sky Tracker lock on the selected aircraft

Aerial tracking SDK

Sky Tracker

A C++ tracking core installable as a Python package. Lock onto a target in one call and get its position every frame - tested at 32+ FPS on a Raspberry Pi live stream, with no GPU and no cloud.

Core
C++
Throughput
180+ FPS @ 720p
Compute
CPU only
See Sky Tracker
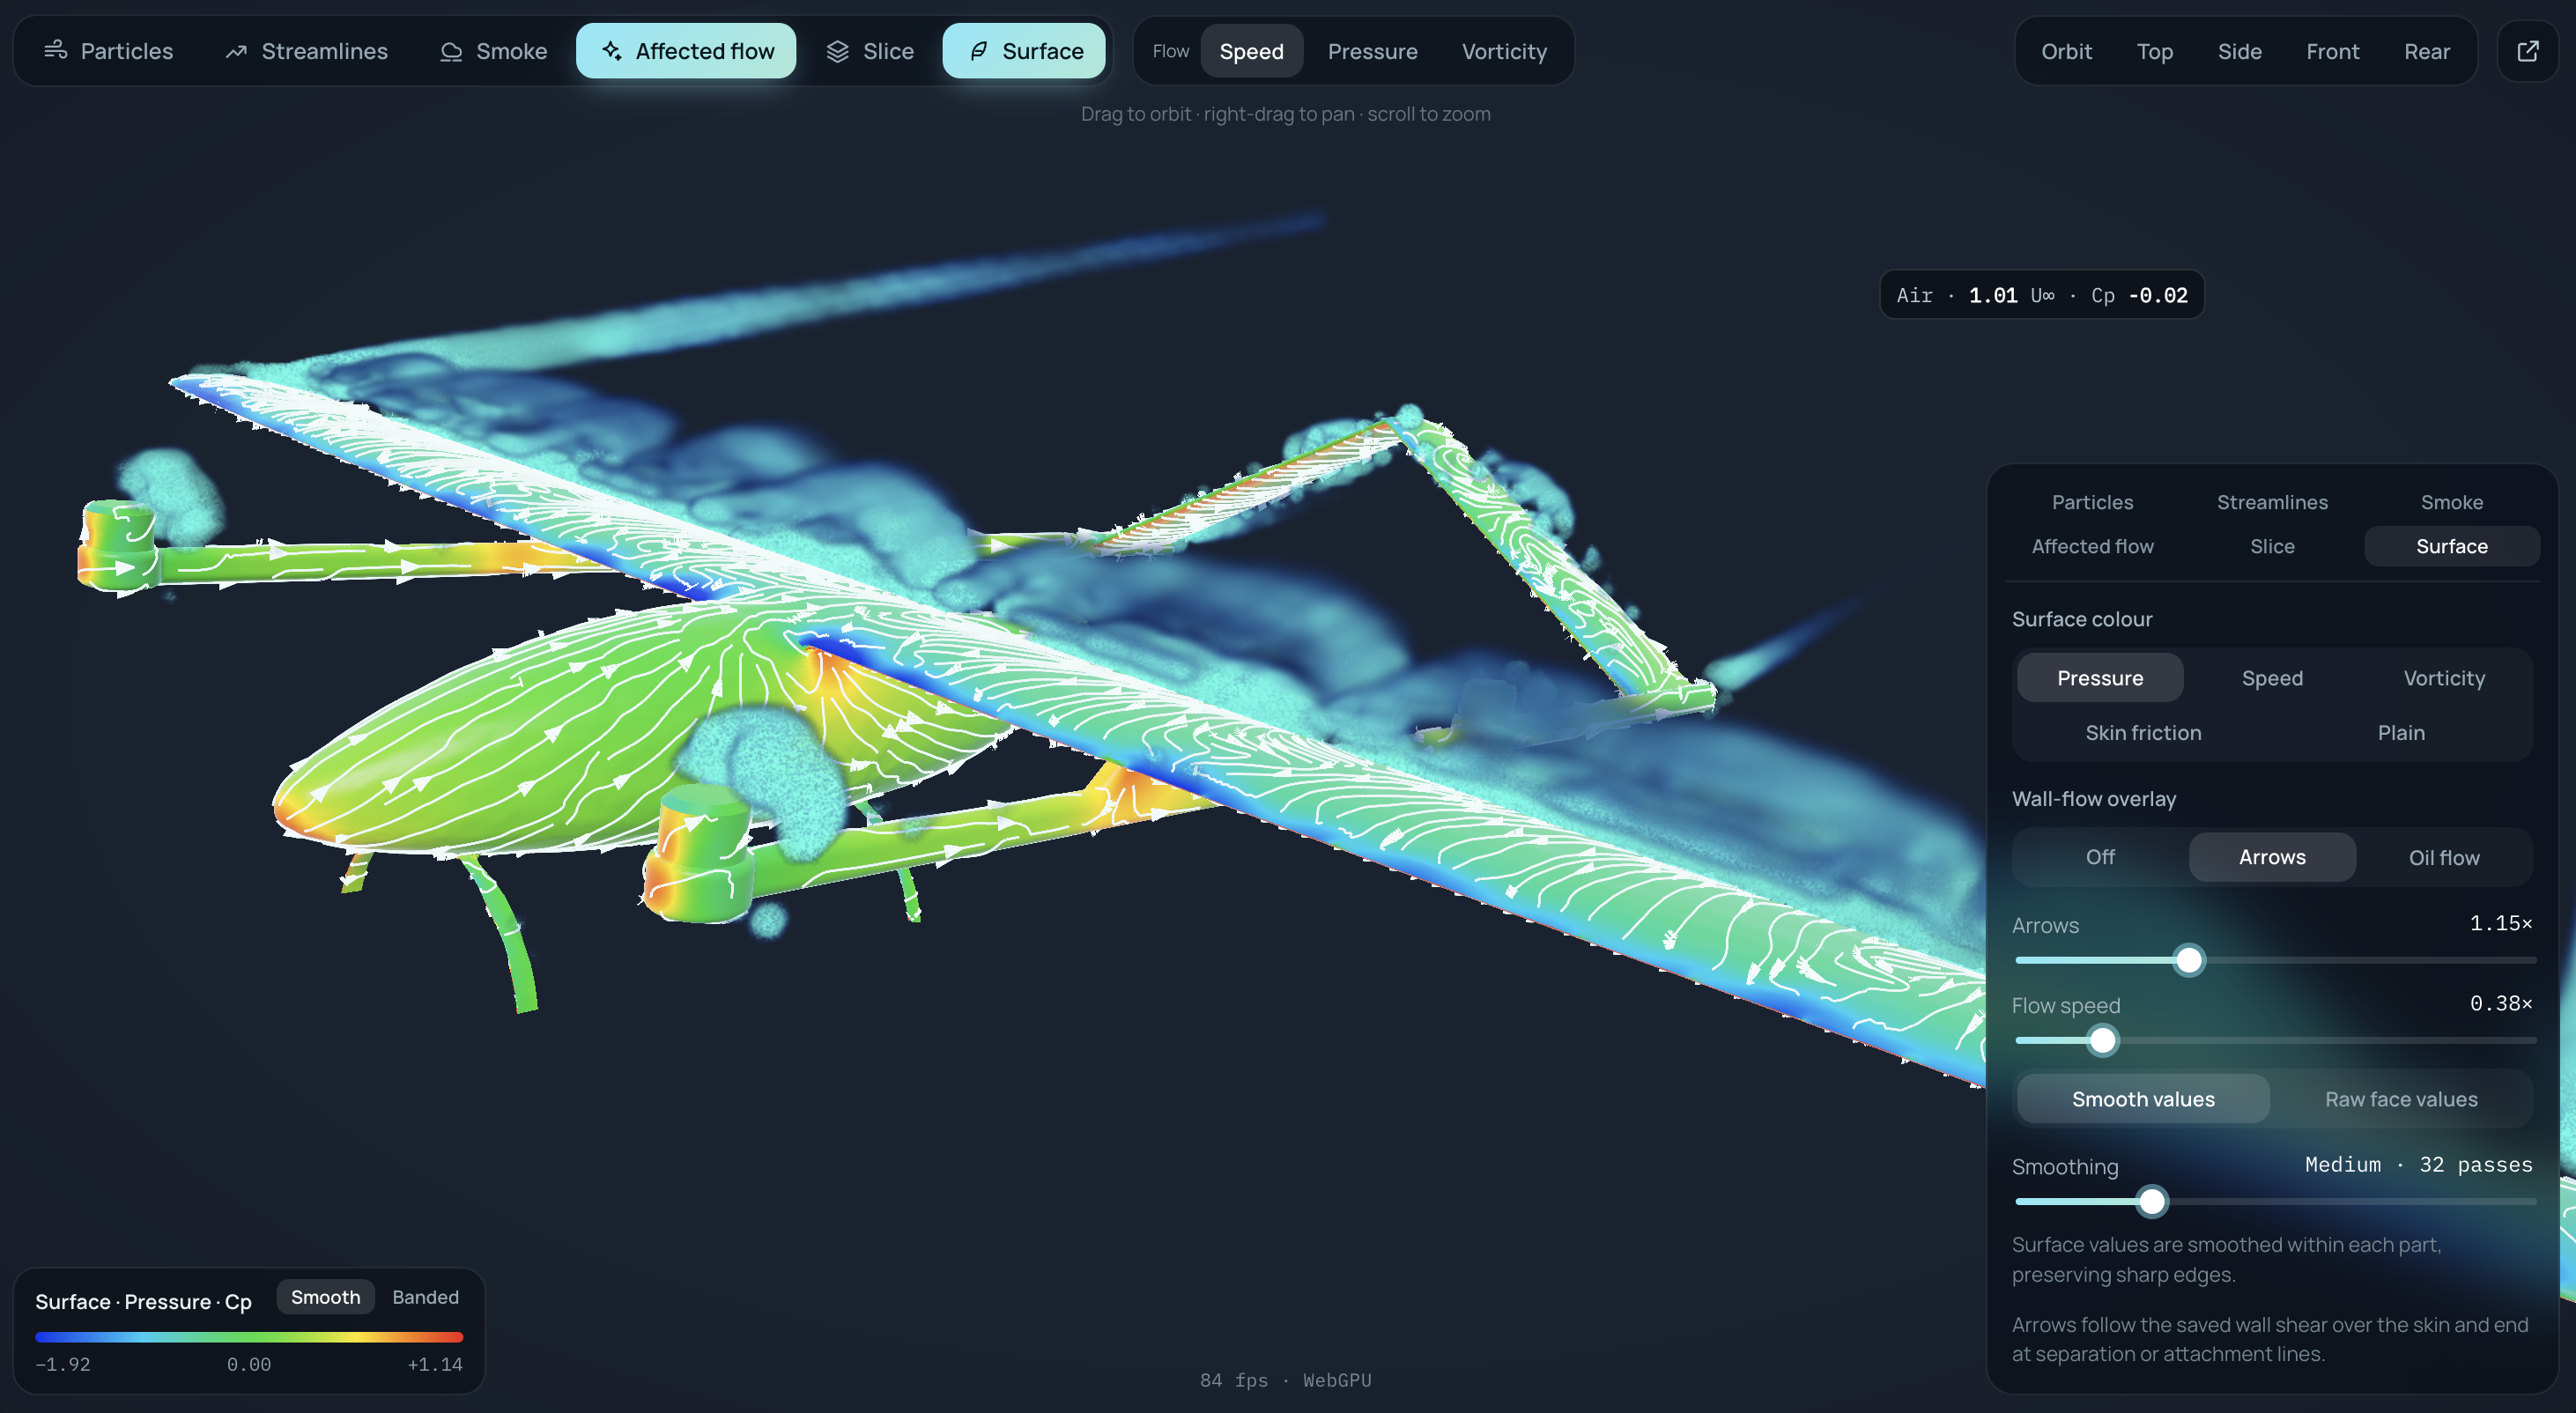
Raven aircraft with surface pressure and airflow visualization in Deneb Aero

Aircraft design & simulation

Deneb Aero

From aircraft CAD to a flight model in one browser workspace. Import STEP or STL geometry, configure controls, run CFD across angles of attack and control deflections, and inspect pressure, lift, drag and moments. Build a Gazebo flight model and export the aircraft, world and simulation settings.

Explore the free AeroLab demo and recorded CAD-to-flight walkthrough today. Hosted CFD and flight for your own aircraft are in development; join the early-access waitlist.

Geometry
STEP / STL
Analysis
Lift, drag & moments
Flight model
Gazebo export
Explore Deneb Aero
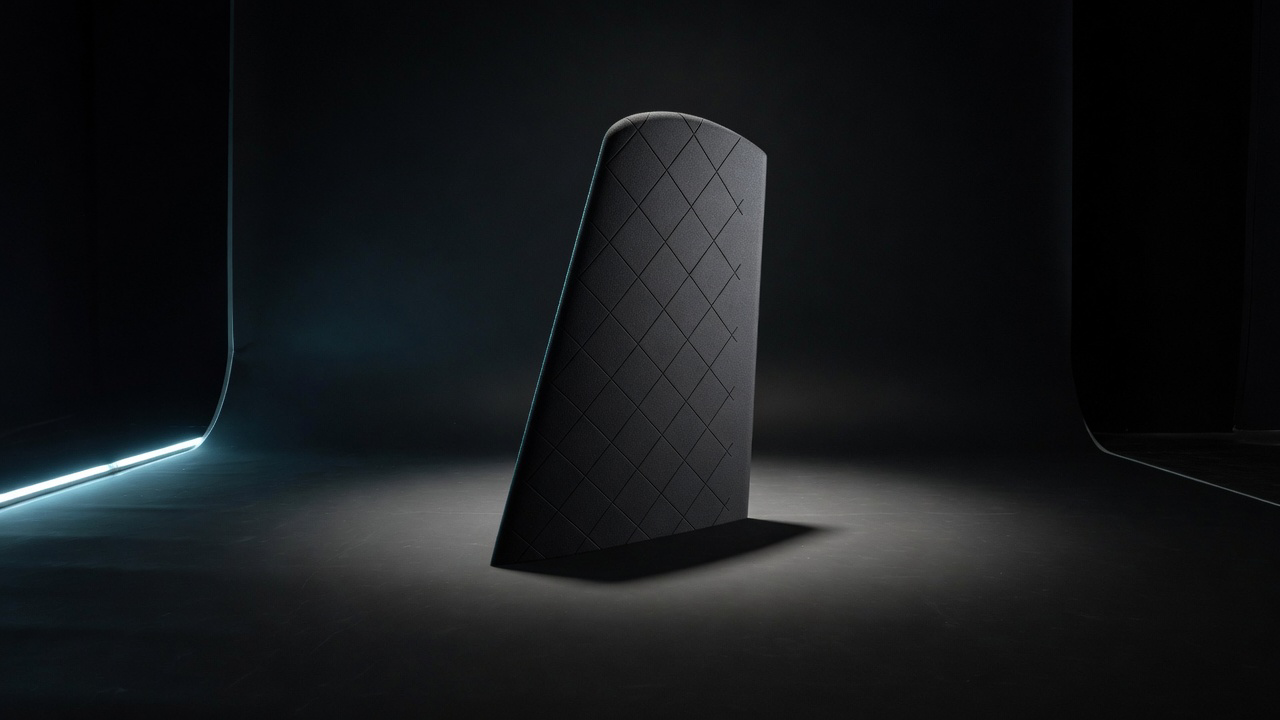
3D-printed UAV wing with a diamond lattice produced by Vase Mode Wing

3D printing

Vase Mode Wing

3D-printing software for UAV wings and airframe parts. Converts a solid into a vase-mode STL — one loop per layer, optional diamond truss — so FDM printers can spiral-print a light, stiff part. Runs in the browser.

Runtime
In-browser
Output
Vase-mode STL
Lattice
Rib pitch + angle
Open Vase Mode Wing

Stack

The same loop flies every airframe.

Deneb Systems is the vision core, the guidance, the flight control, and the aircraft — not a camera kit bolted onto someone else's platform.

  • Perception

    Lock the target

    Camera-based detection and persistent visual tracking. Sky Tracker runs on CPU, including Raspberry Pi class hardware, with no GPU and no cloud.

  • Guidance

    Stay on the object

    Image-relative motion and inertial fusion turn pixels into flight corrections. No target GPS required.

  • Flight

    Close the loop on the airframe

    Raven, Alien, and Vulture fly that loop onboard — VTOL cargo, interceptor, and loitering munition — with ArduPilot in the control path.

  • Simulation

    Prove it before the airframe

    Gazebo and software-in-the-loop come first. Hardware flies after the same stack has already been exercised against moving aerial targets.

Status

What's proven, and what is still in simulation.

First flights, visual tracking, and simulation are listed separately from work that has only been shown in the loop. We do not publish development targets as production specifications.

WorkStatus
Raven VTOL first flightDemonstrated
Alien interceptor first flightDemonstrated
Vulture first flightDemonstrated
Sky Tracker CPU tracking on live videoDemonstrated
Camera-based target detectionDemonstrated
Persistent visual trackingDemonstrated
Gazebo interceptor simulationDemonstrated
Autonomous pursuit logicDemonstrated in simulation